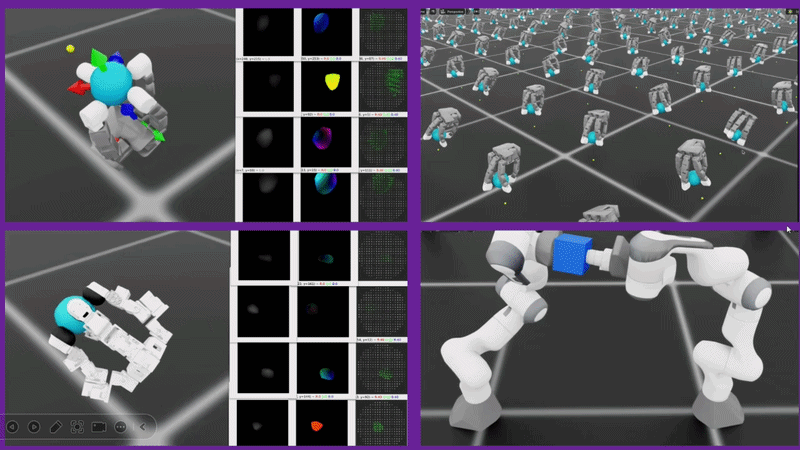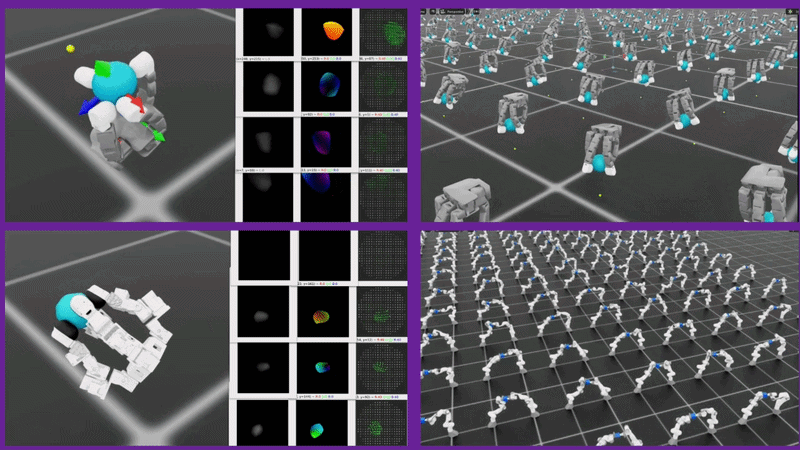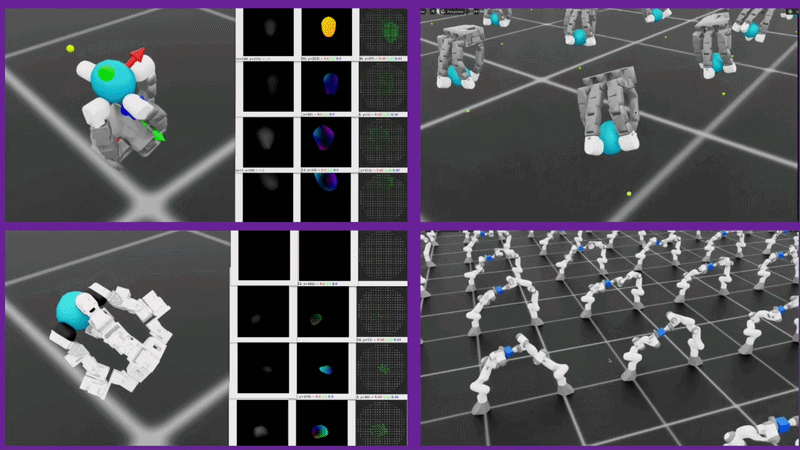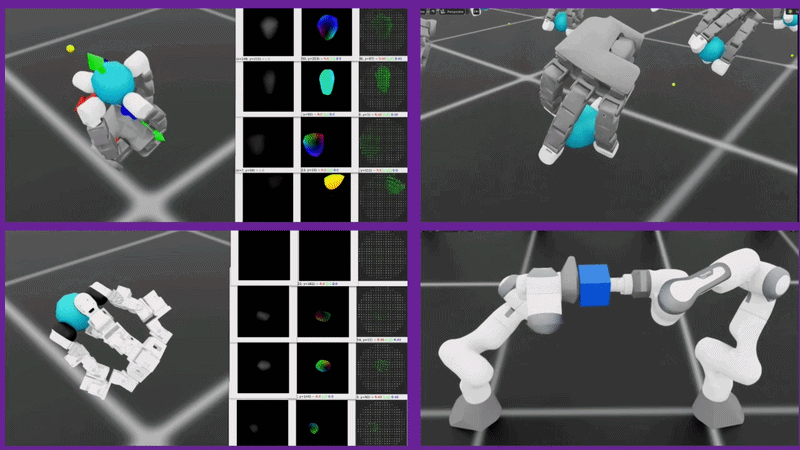
We develop robots that learn to perceive and interact with the physical world through touch. Our research combines tactile sensing, multimodal perception, and robot learning to enable dexterous manipulation in complex, contact-rich environments.
We focus on three closely connected research directions:
Tactile sensing and perception: Understanding contact, geometry, and motion through vision-based tactile sensors and multimodal representations.
Simulation and robot learning: Building scalable tactile simulation and sim-to-real learning methods that transfer robot skills from virtual environments to the real world.
Dexterous robotic manipulation: Developing touch-guided skills for in-hand manipulation, bimanual coordination, and precise contact-rich tasks.
Links
Copyright, 2026