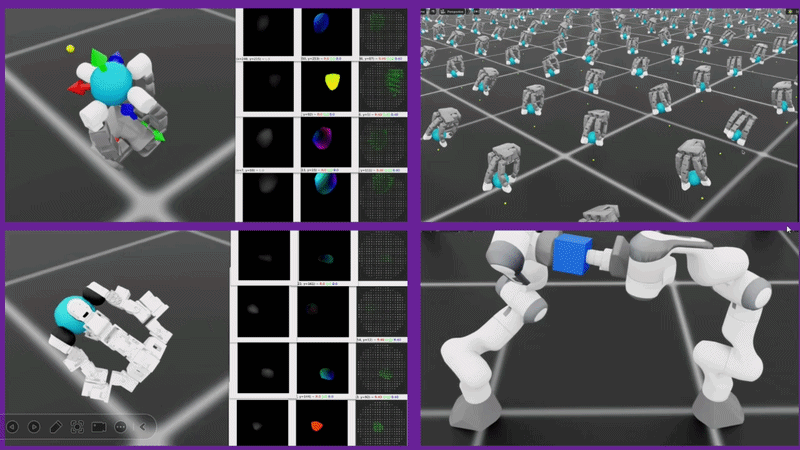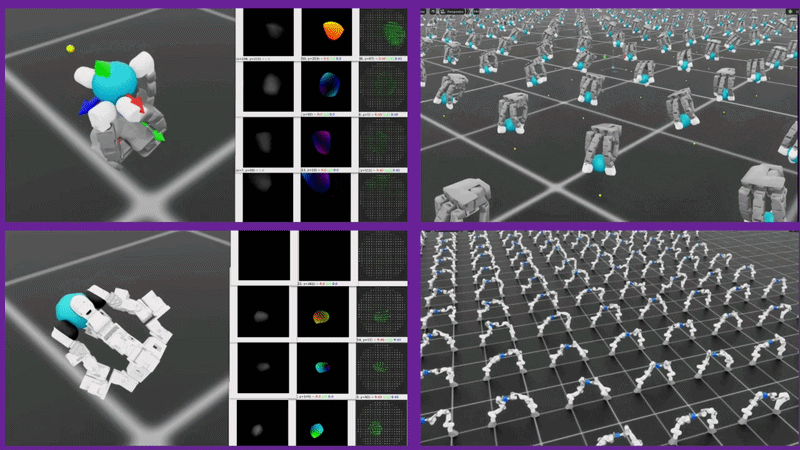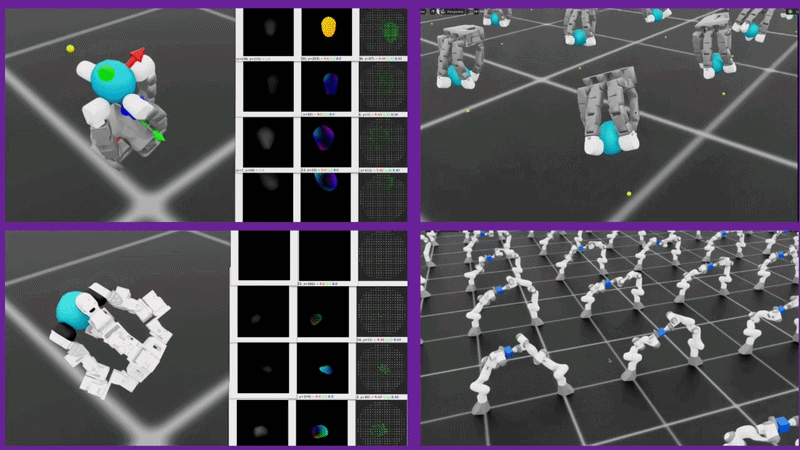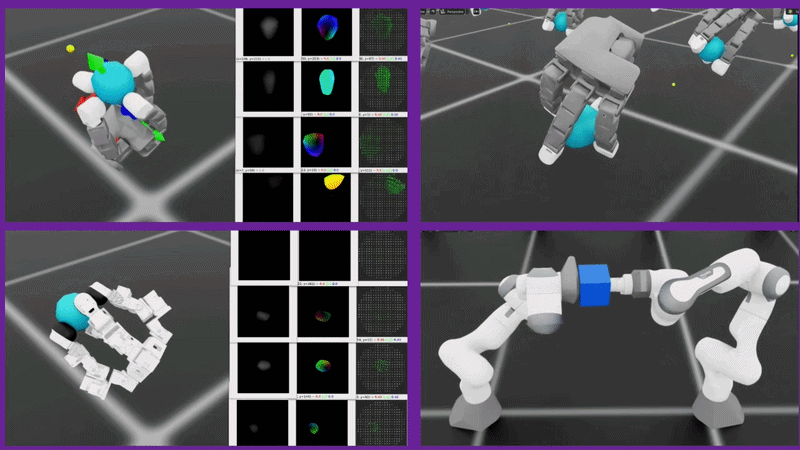
TactileLab: Efficient Multimodal Tactile Simulation for Shear-Sensitive Dexterous Sim2Real Robotic Manipulation
arXiv, 2026 · Coming soon
For more up-to-date information, please refer to Google Scholar.
The following work was primarily completed at the University of Bristol.
TactileLab: Efficient Multimodal Tactile Simulation for Shear-Sensitive Dexterous Sim2Real Robotic Manipulation
arXiv, 2026 · Coming soon
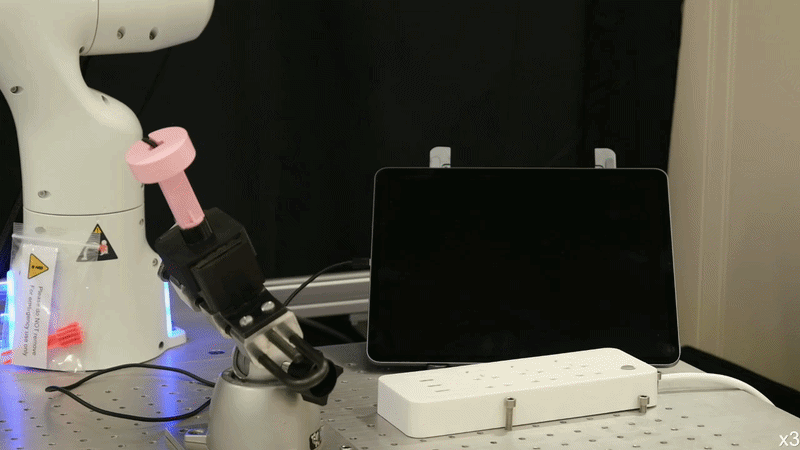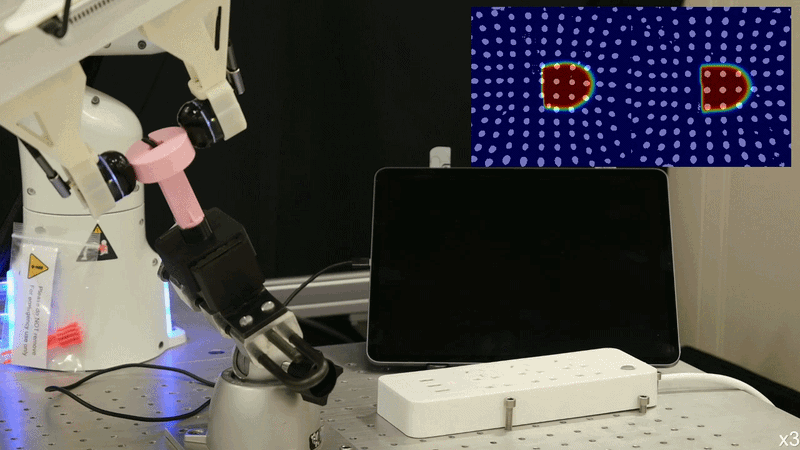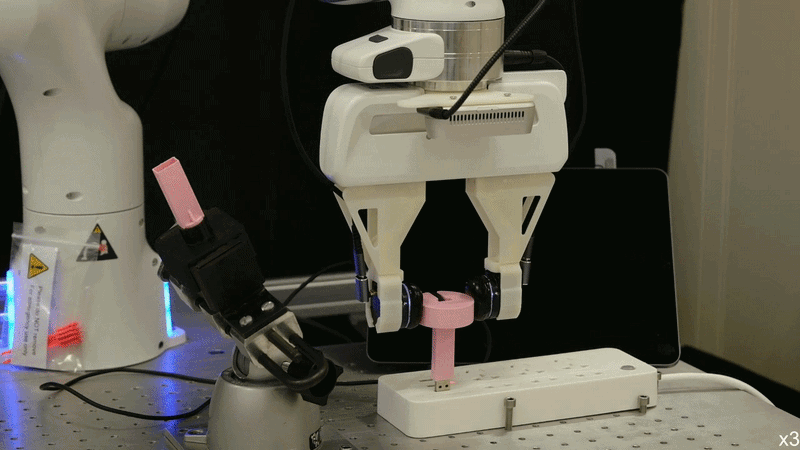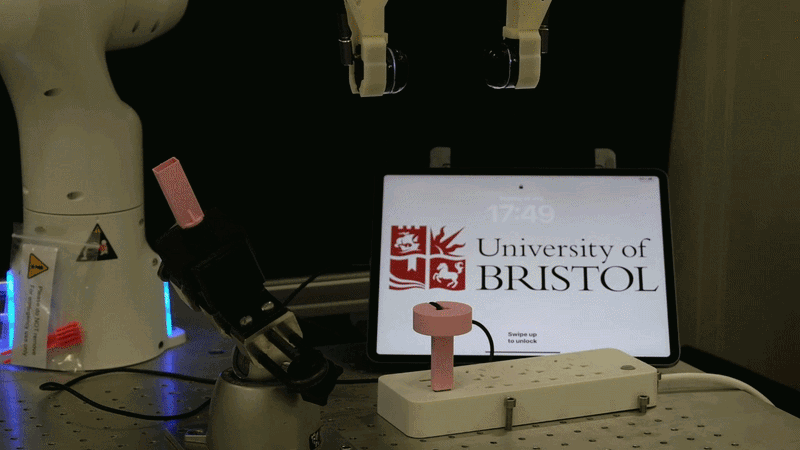
NeuralTouch: Neural Descriptors for Precise Sim-to-Real Tactile Robot Control
IEEE/ASME Transactions on Mechatronics (TMECH), 2026
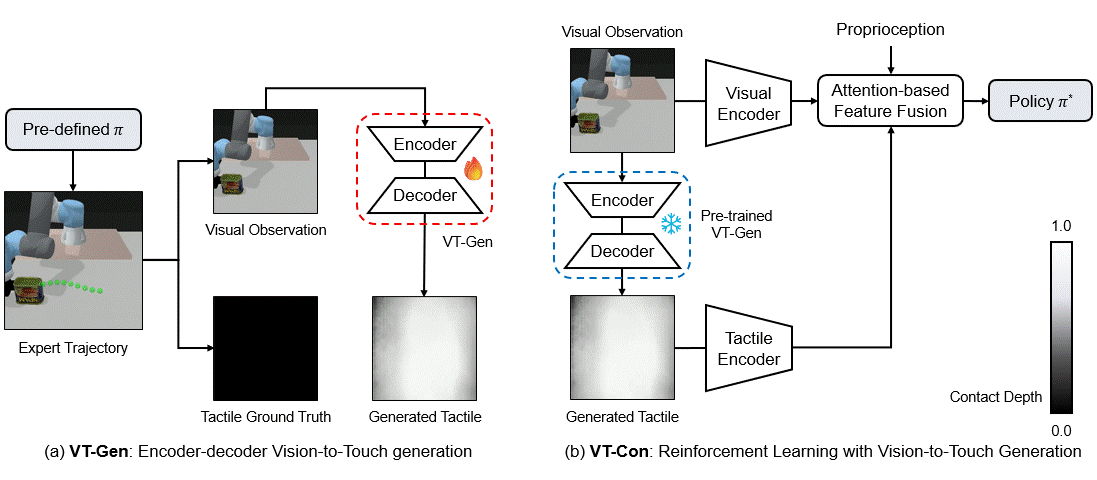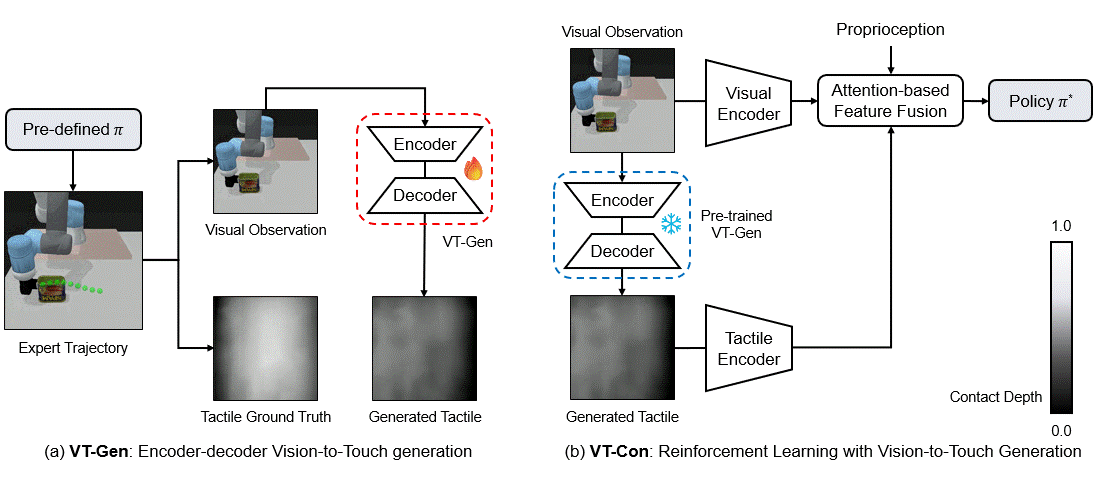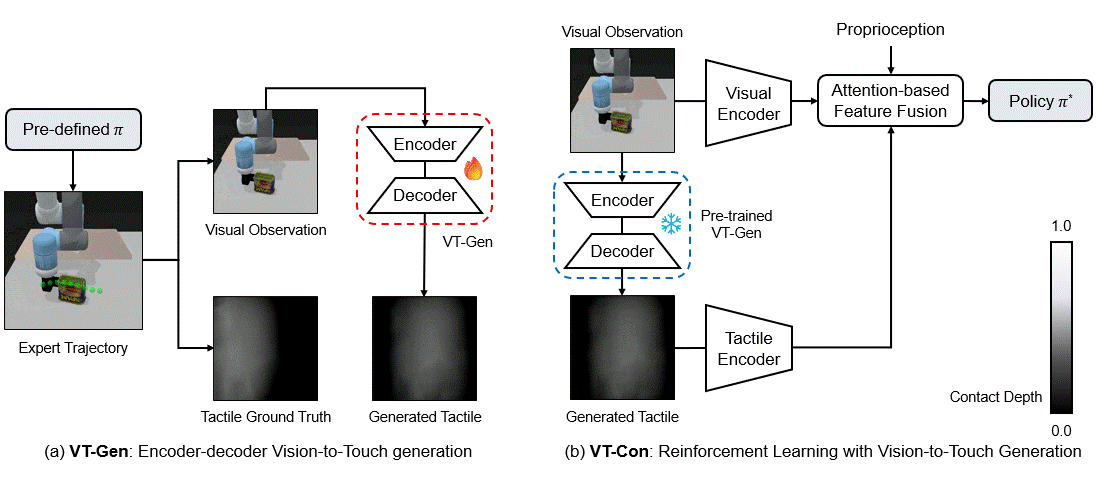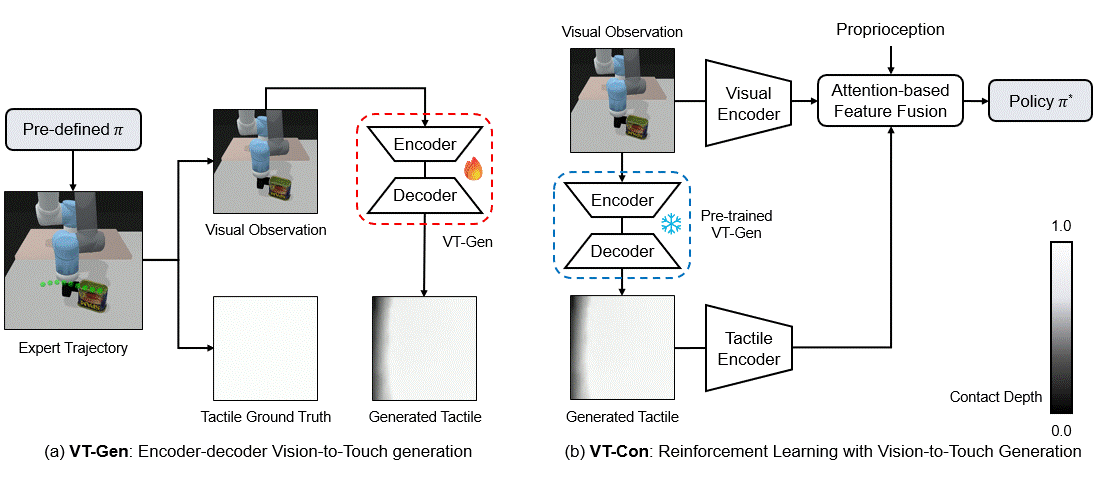
ViTacGen: Robotic Pushing with Vision-to-Touch Generation
IEEE Robotics and Automation Letters (RA-L), 2025
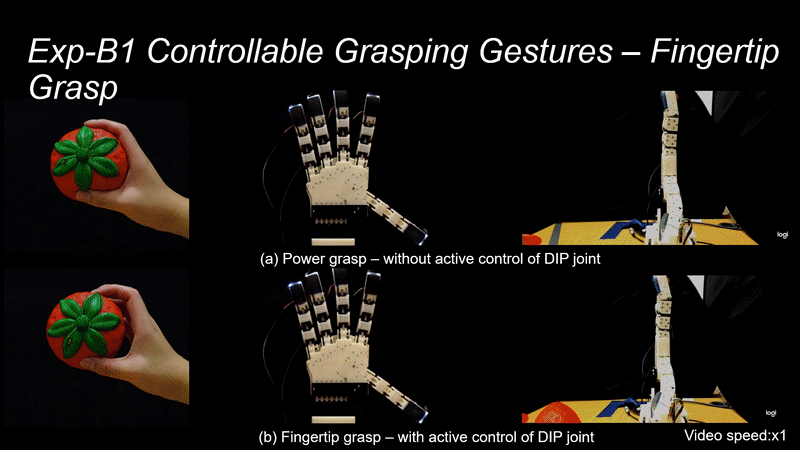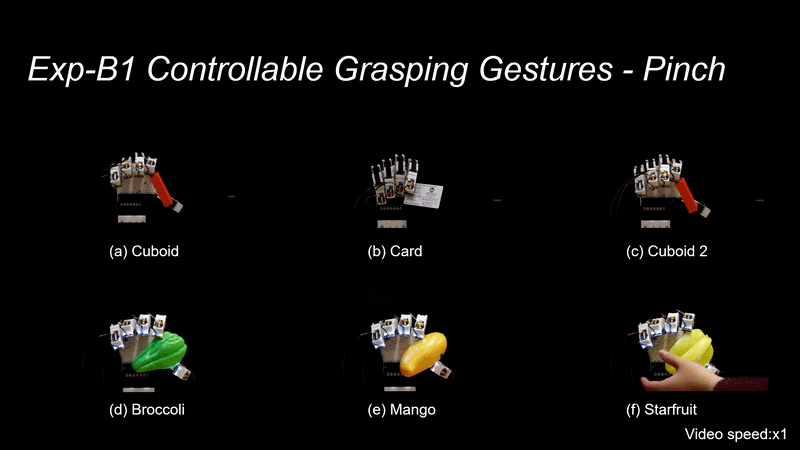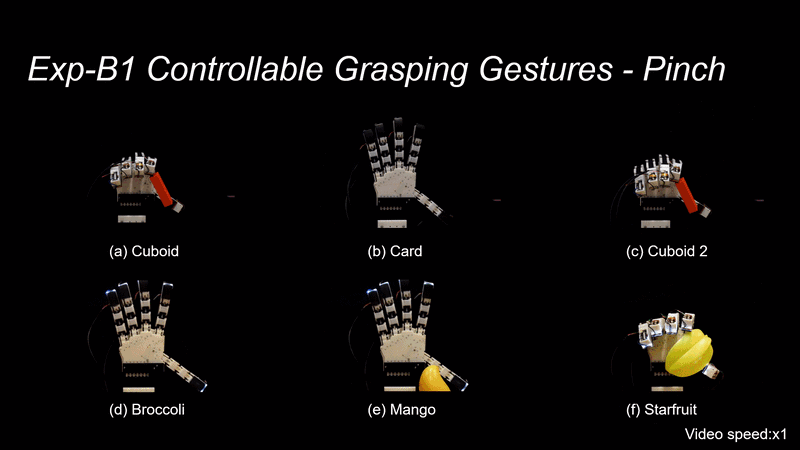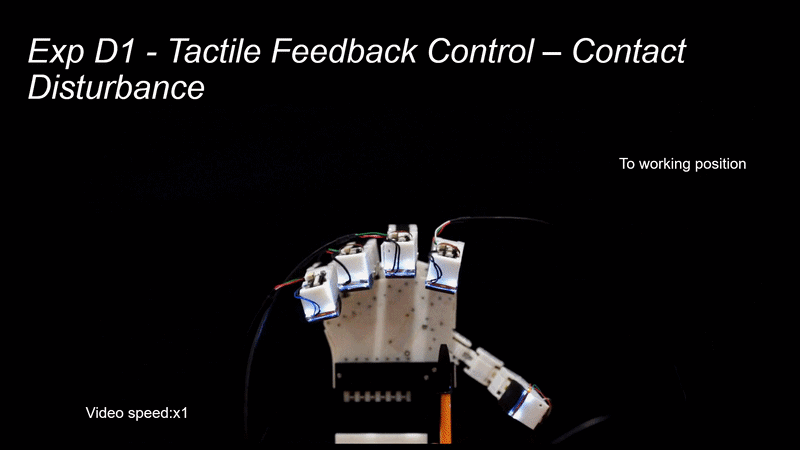
Tactile SoftHand-A: 3D-Printed, Tactile, Highly-Underactuated, Anthropomorphic Robot Hand with an Antagonistic Tendon Mechanism
The International Journal of Robotics Research (IJRR), 2025
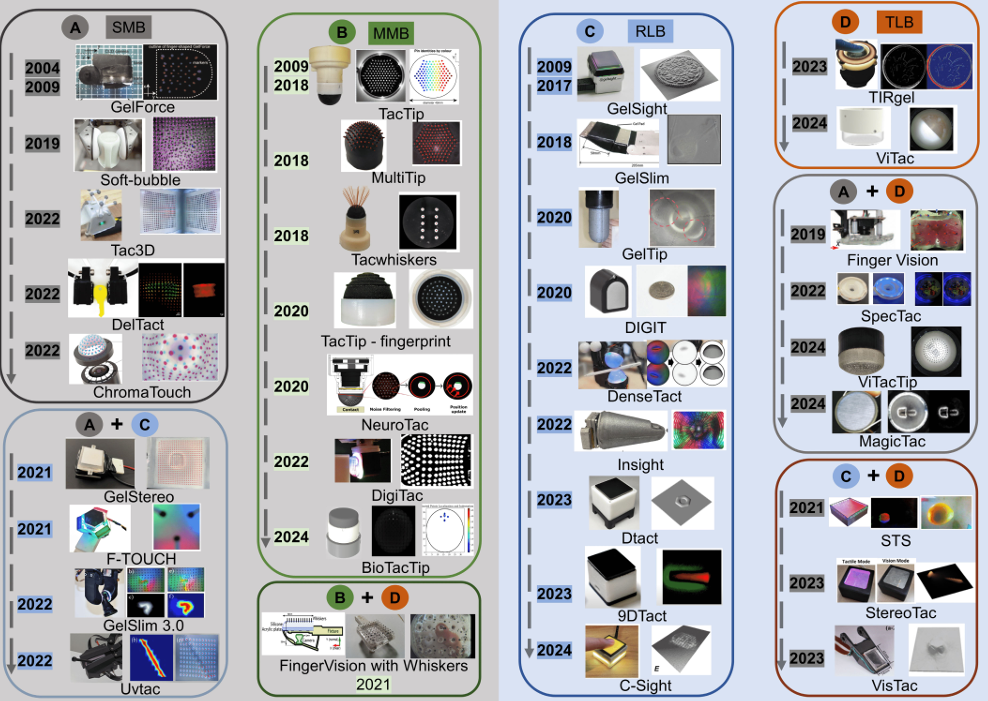
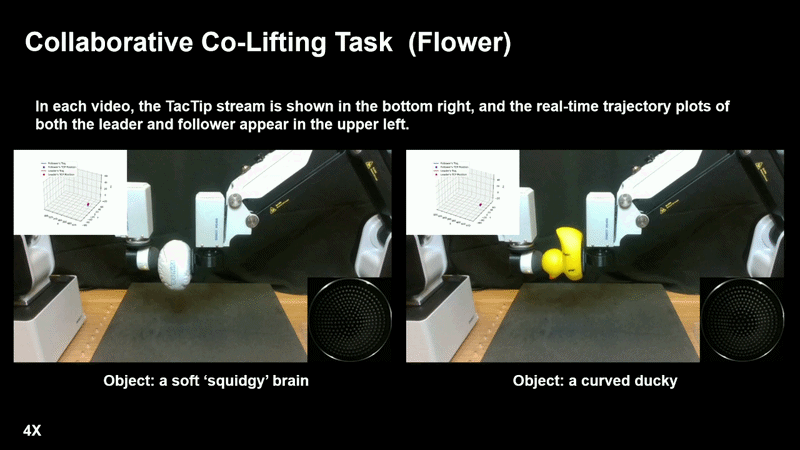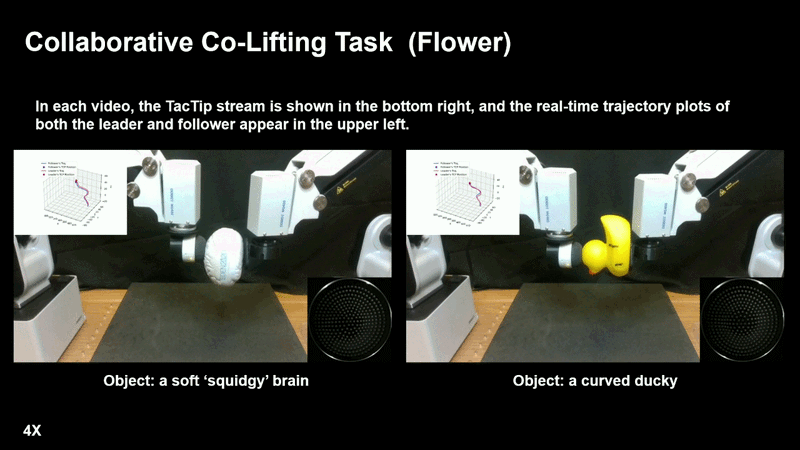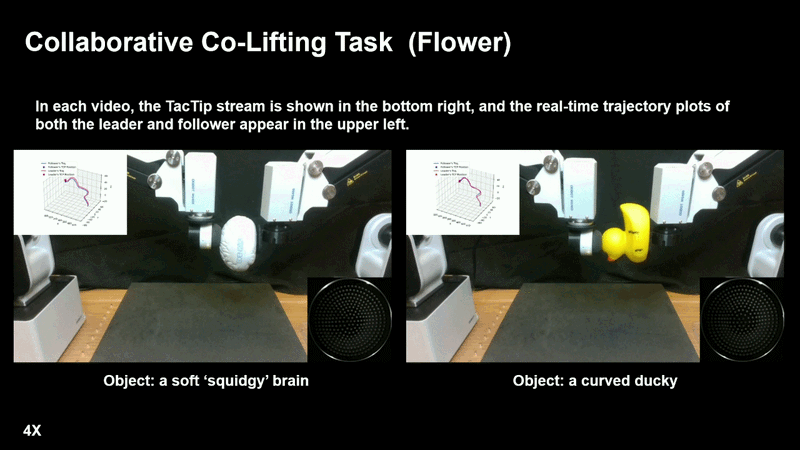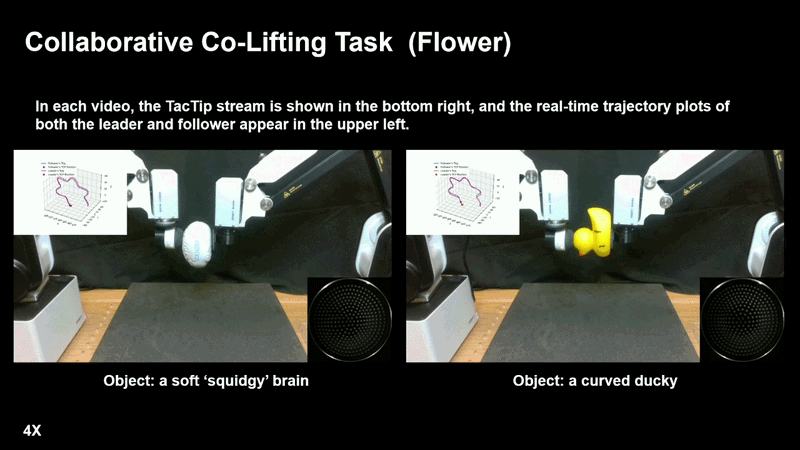
SimShear: Sim-to-Real Shear-based Tactile Servoing
9th Annual Conference on Robot Learning (CoRL), 2025
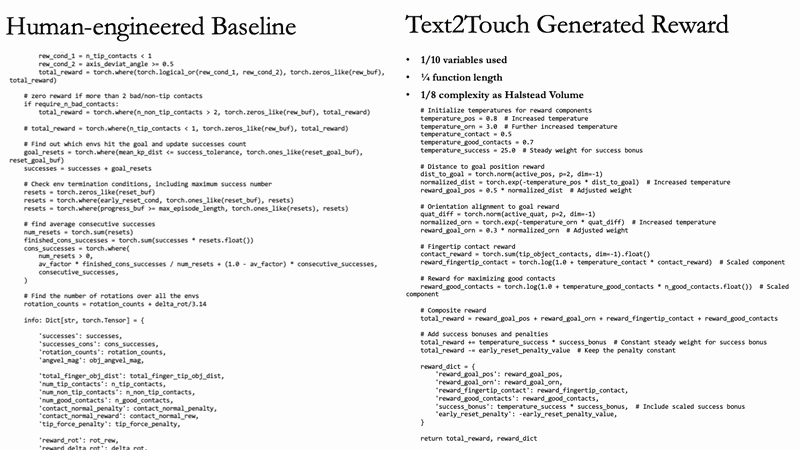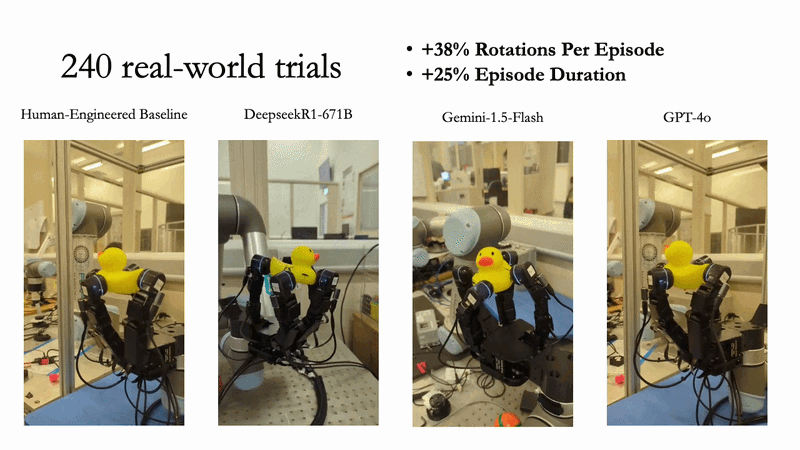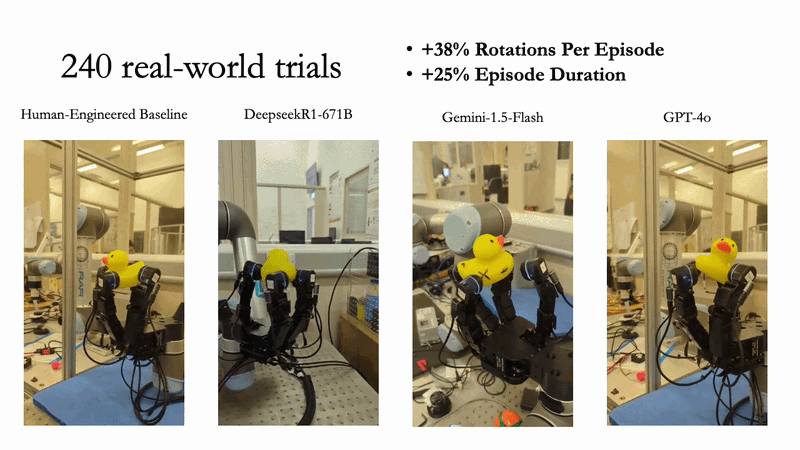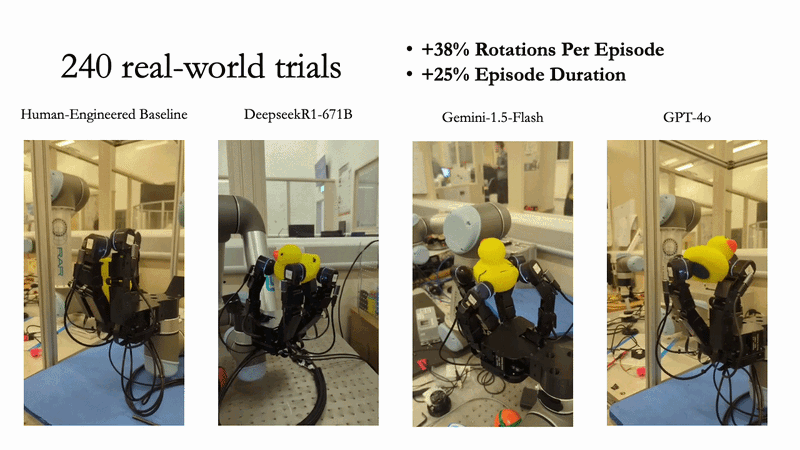
Text2Touch: Tactile In-Hand Manipulation with LLM-Designed Reward Functions
9th Annual Conference on Robot Learning (CoRL), 2025
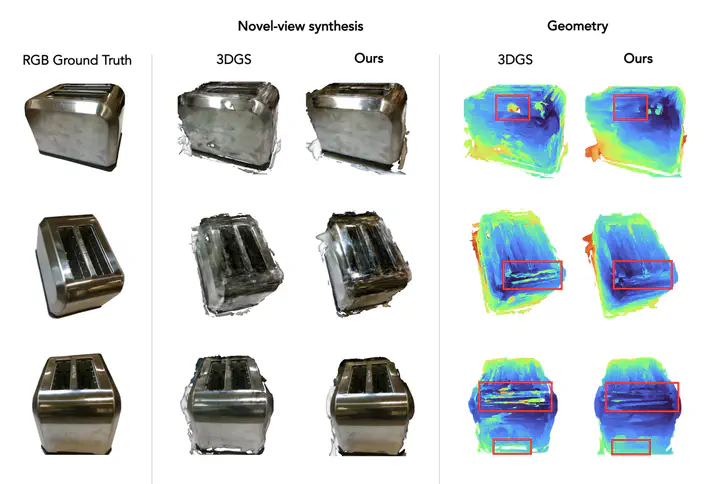
Snap-it, tap-it, splat-it: Tactile-informed 3D Gaussian splatting for reconstructing challenging surfaces
International Conference on 3D Vision, 2025
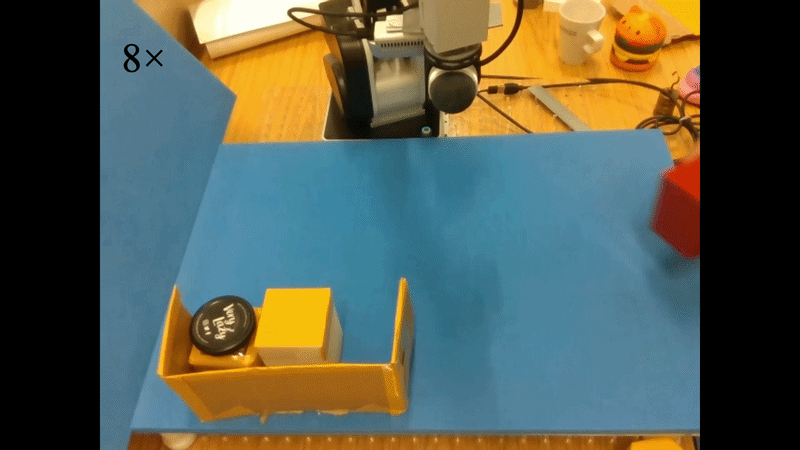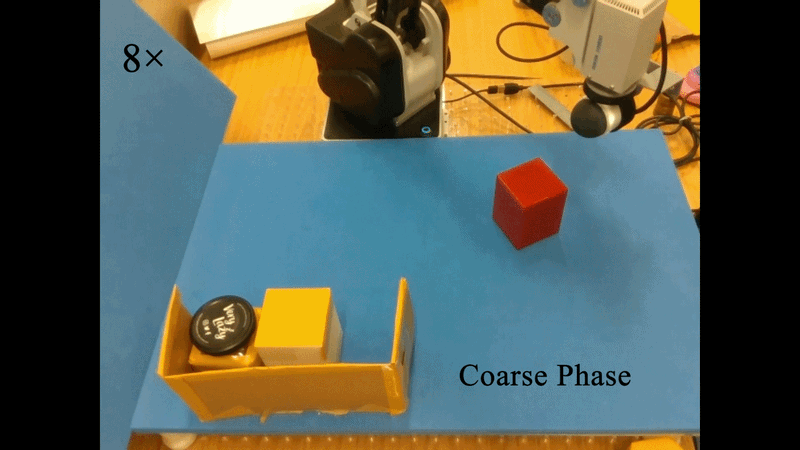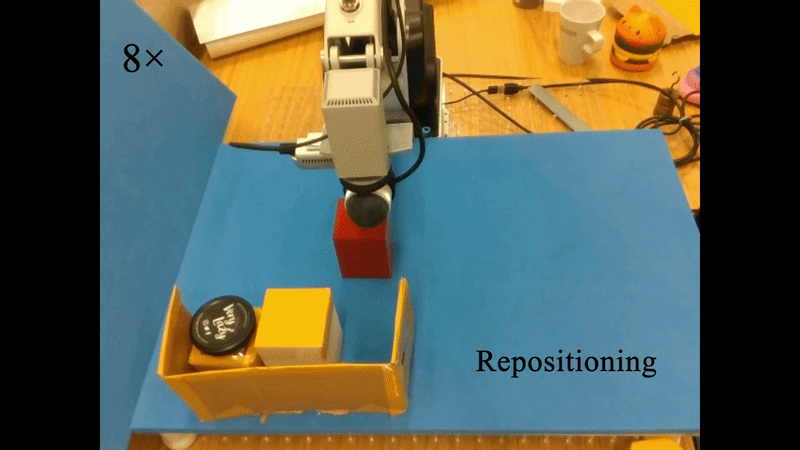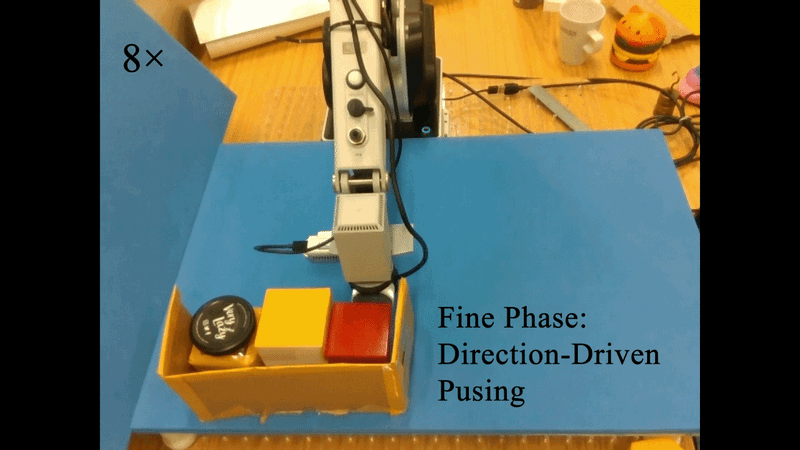
Coarse-to-fine Robotic Pushing using Touch, Vision and Proprioception
IEEE Robotics and Automation Letters (RA-L), 2025
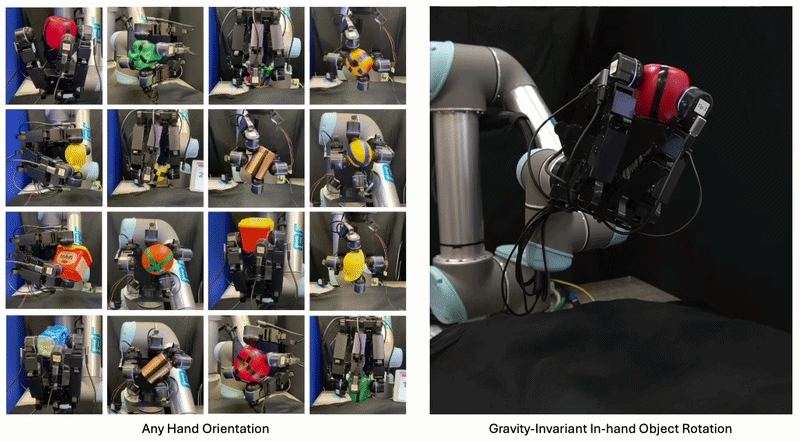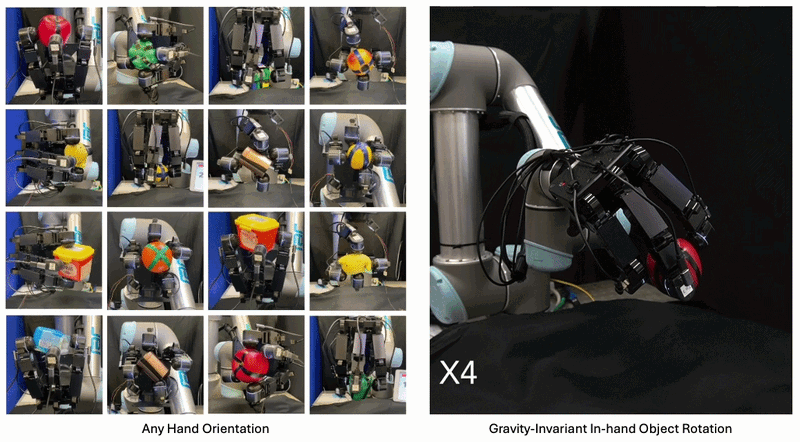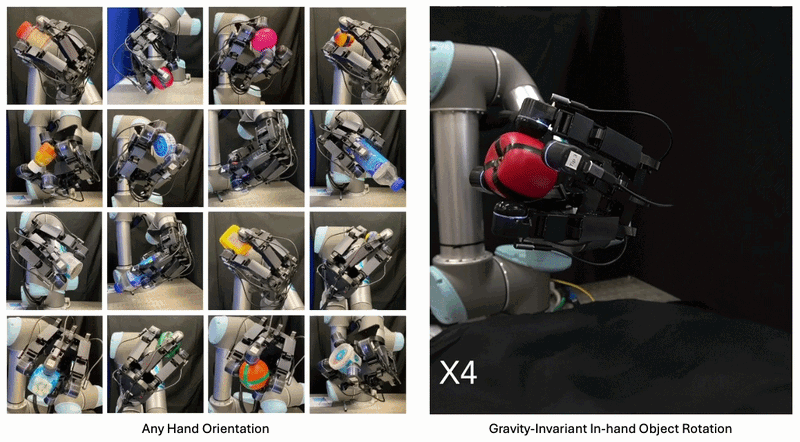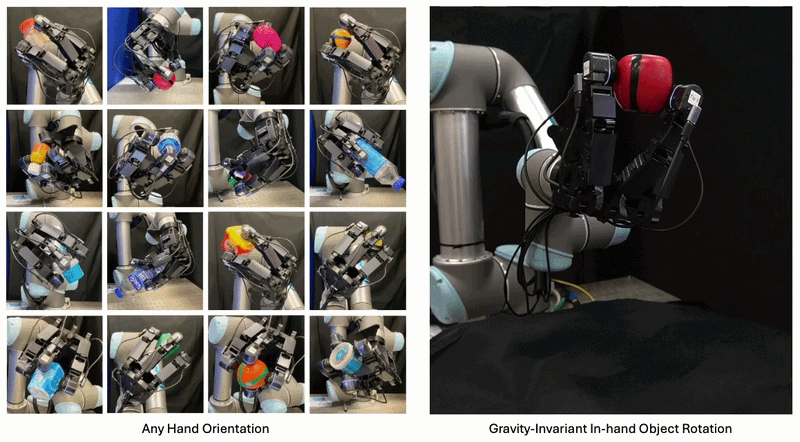
Anyrotate: Gravity-invariant in-hand object rotation with sim-to-real touch
8th Annual Conference on Robot Learning (CoRL), 2024
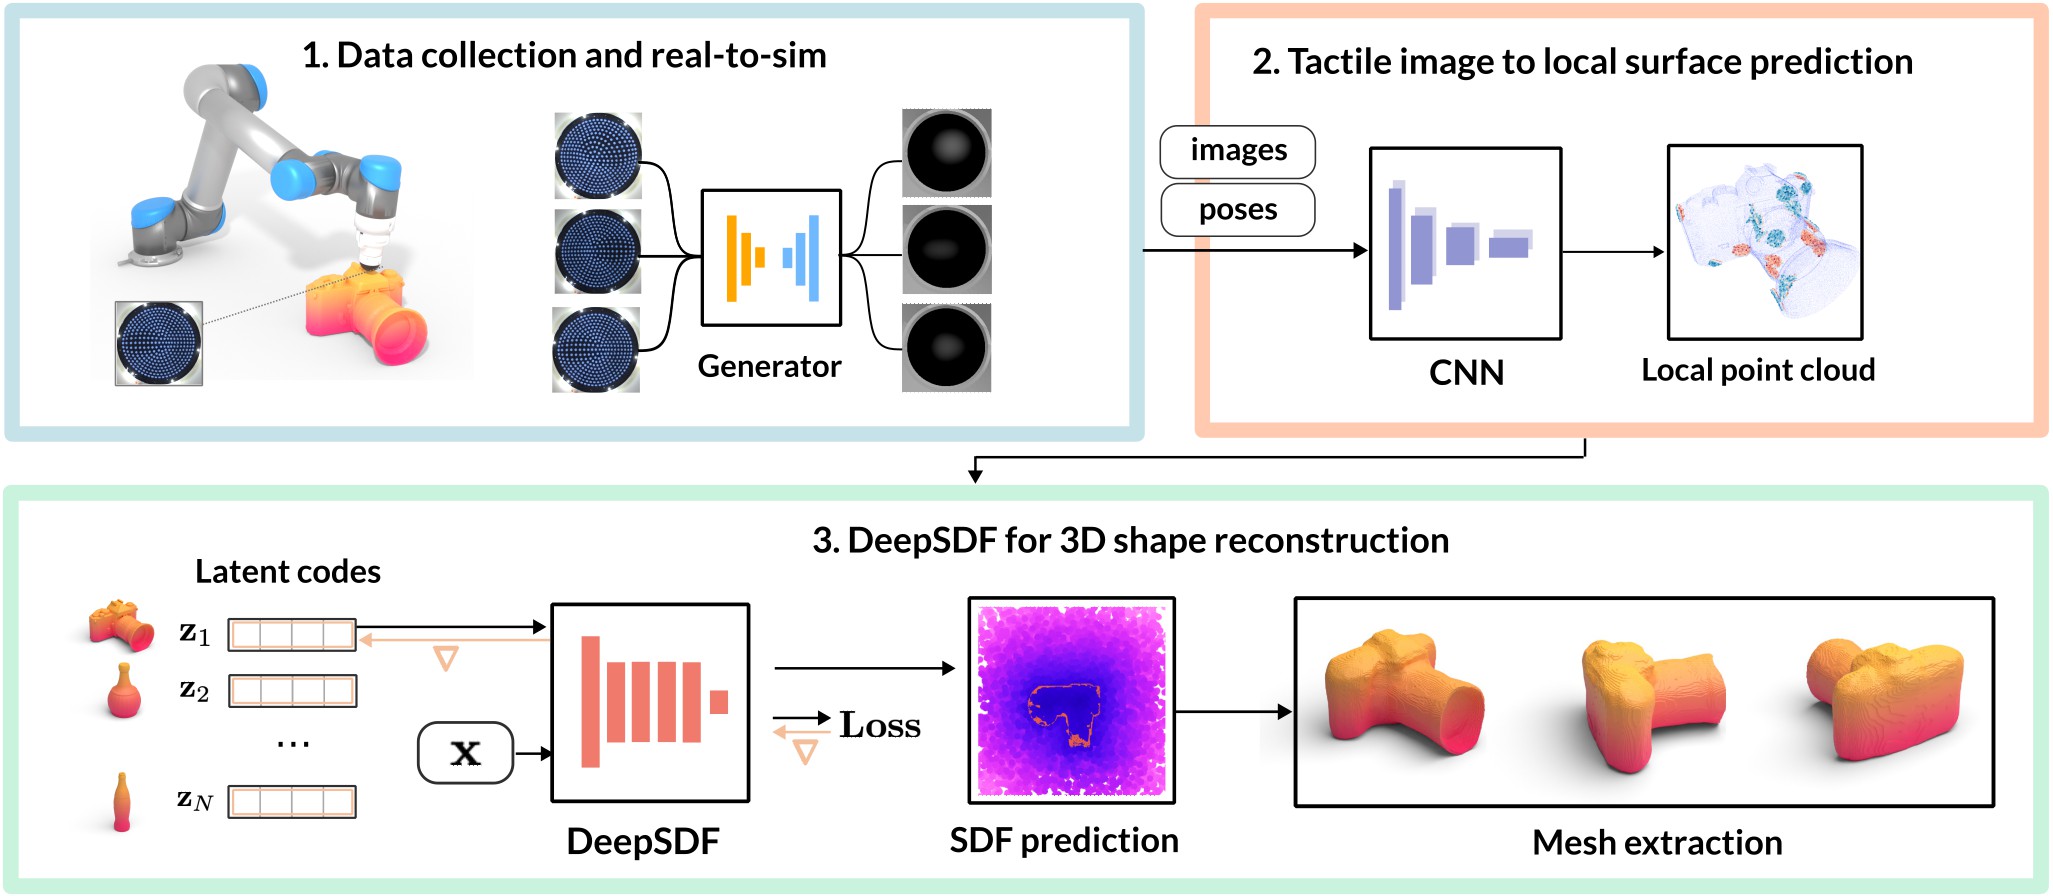
Touchsdf: A deepsdf approach for 3d shape reconstruction using vision-based tactile sensing
IEEE Robotics and Automation Letters (RA-L), 2024
Sim-to-real model-based and model-free deep reinforcement learning for tactile pushing
IEEE Robotics and Automation Letters (RA-L), 2023
Bi-Touch: Bimanual Tactile Manipulation With Sim-to-Real Deep Reinforcement Learning
IEEE Robotics and Automation Letters (RA-L), 2023
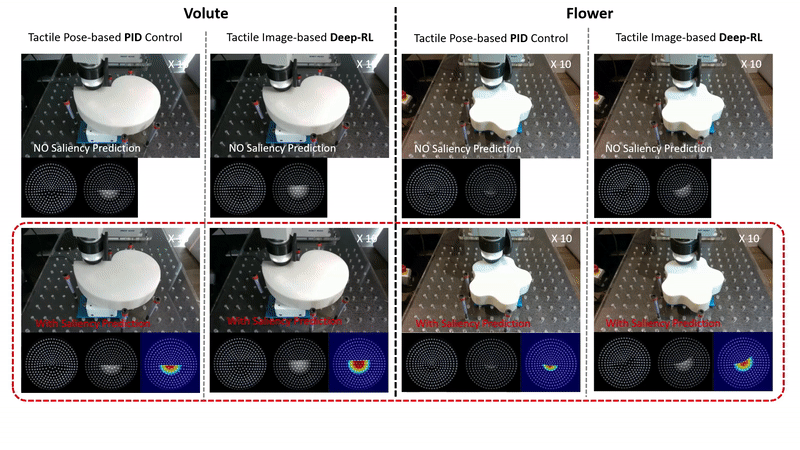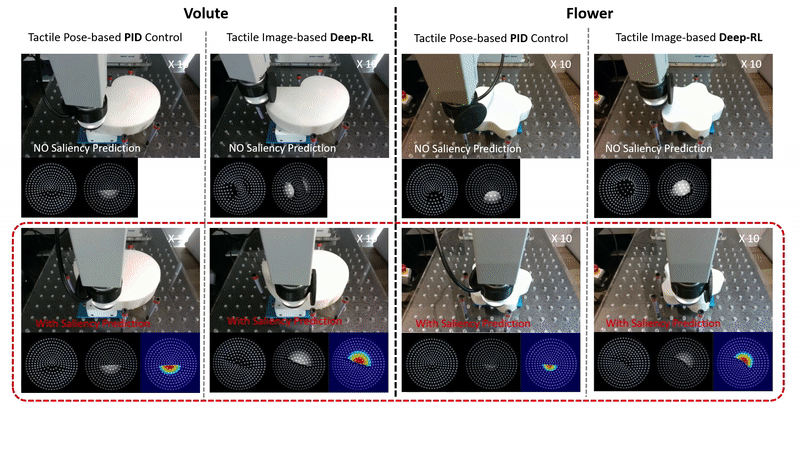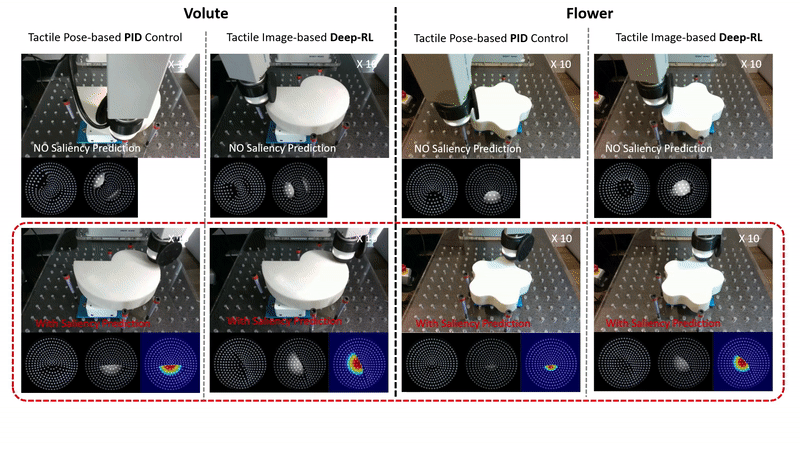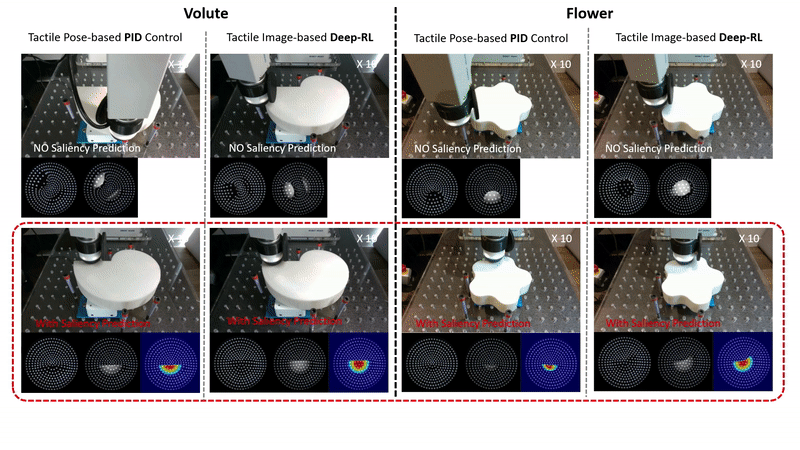
Attention for Robot Touch: Tactile Saliency Prediction for Robust Sim-to-Real Tactile Control
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2023
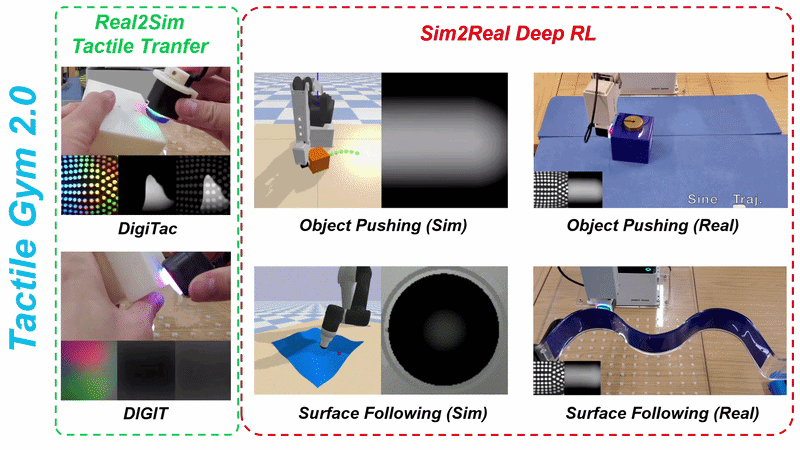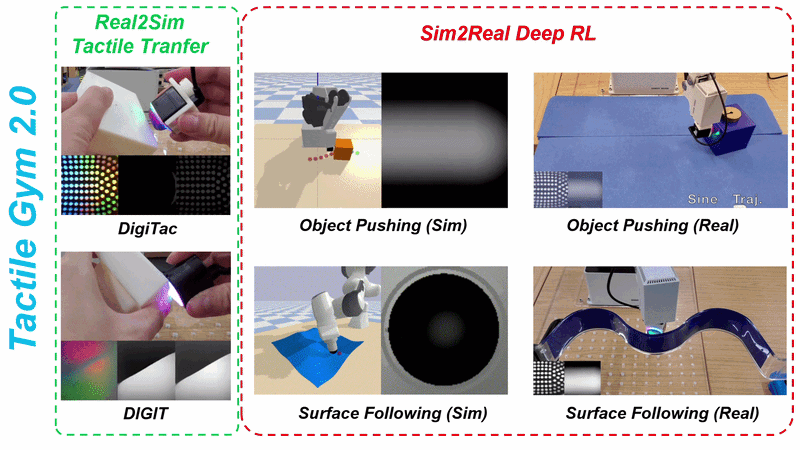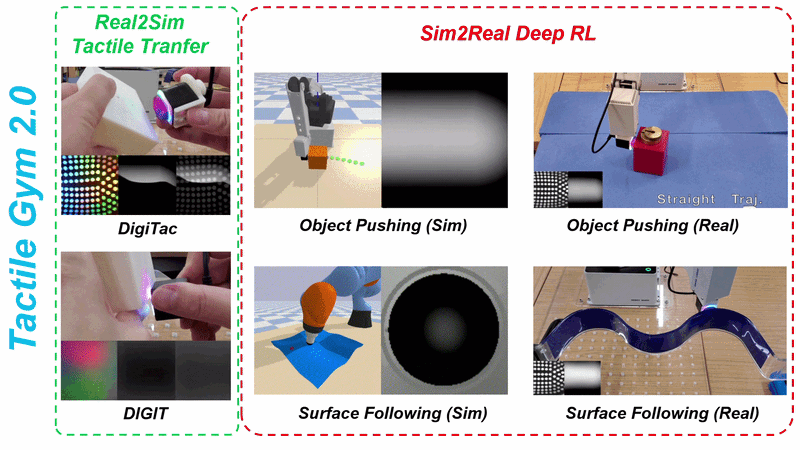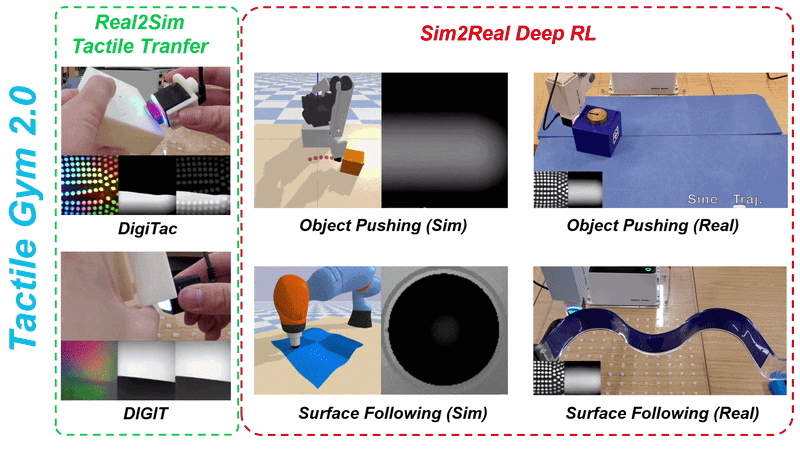
Tactile Gym 2.0: Sim-to-real Deep Reinforcement Learning for Comparing Low-cost High-Resolution Robot Touch
IEEE Robotics and Automation Letters (RA-L), Aug 2022
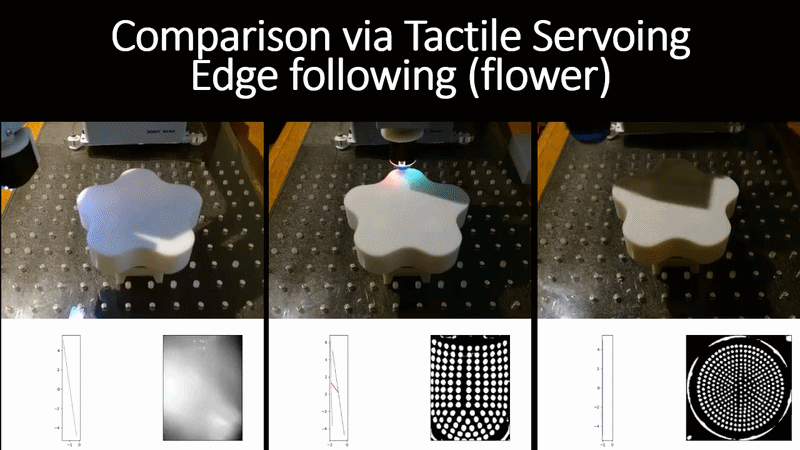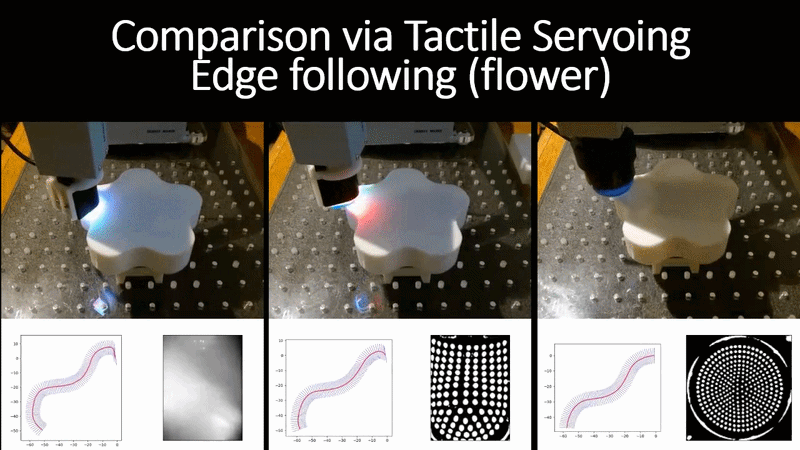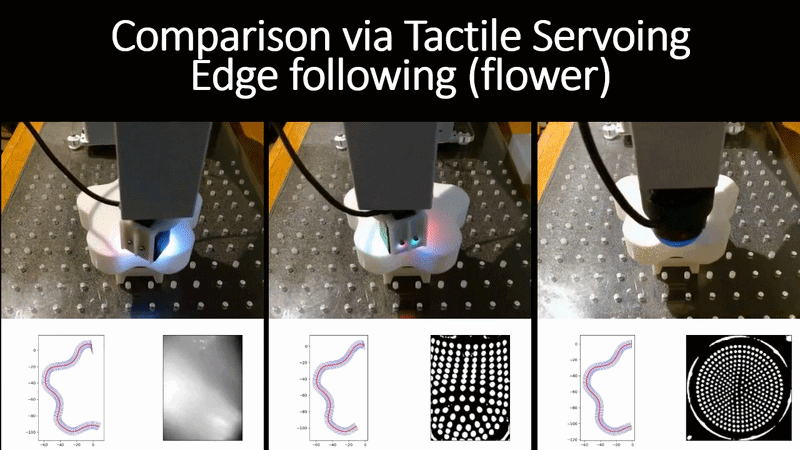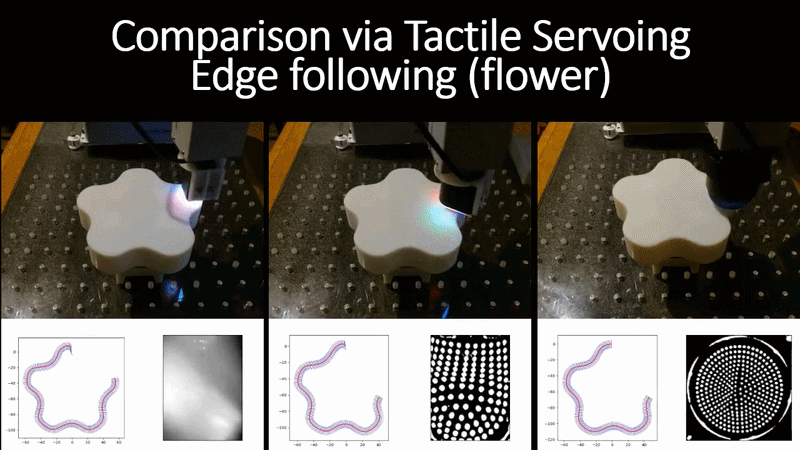
DigiTac: A DIGIT-TacTip Hybrid Tactile Sensor for Comparing Low-Cost High-Resolution Robot Touch
IEEE Robotics and Automation Letters (RA-L), Aug 2022
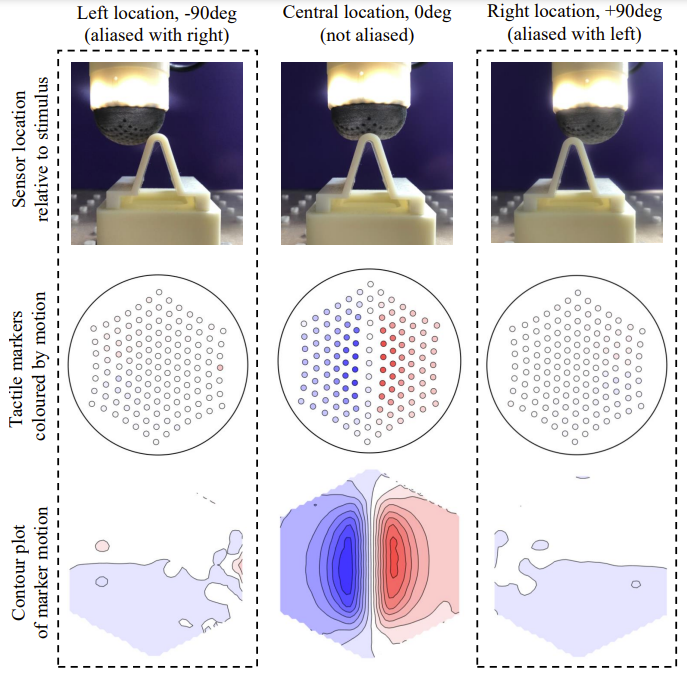
Probabilistic Discriminative Models address the Tactile Perceptual Aliasing Problem
Robotics: Science and Systems (RSS), Jul 2021
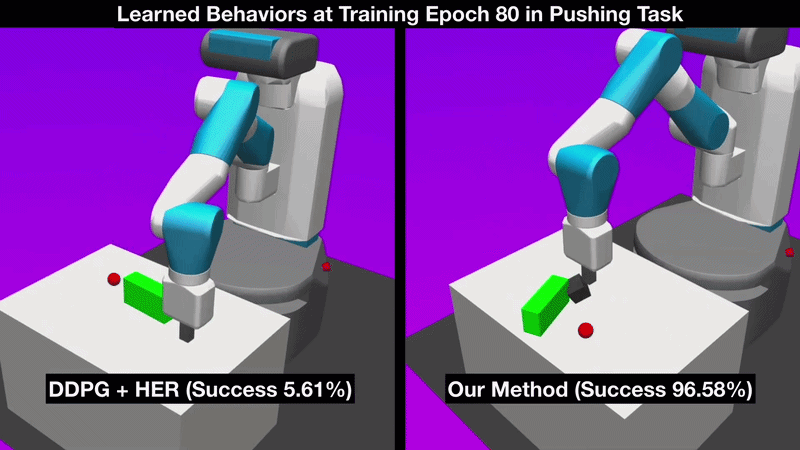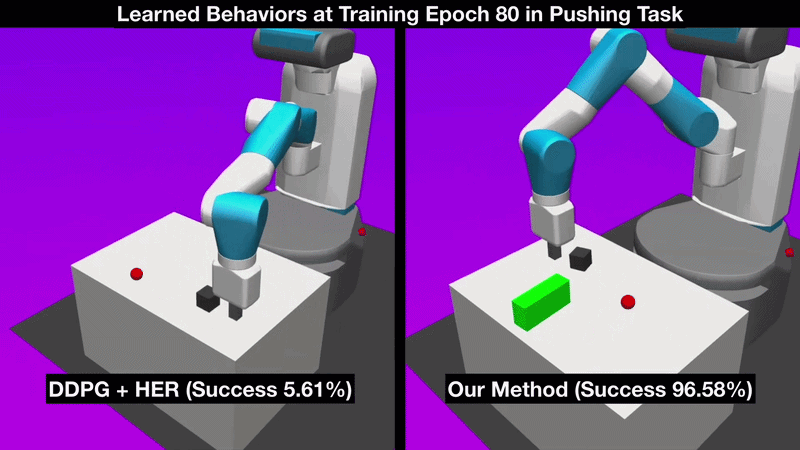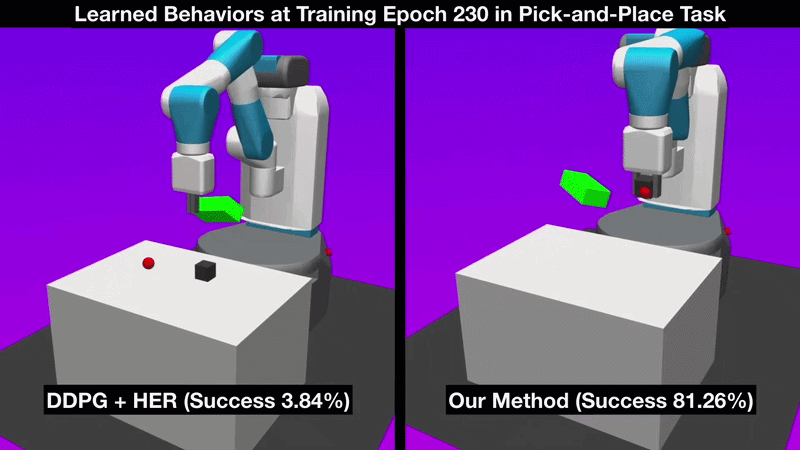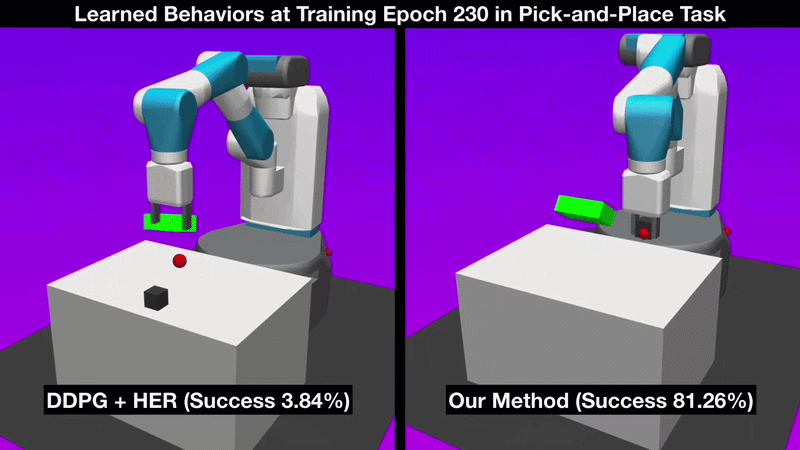
Invariant Transform Experience Replay: Data Augmentation for Deep Reinforcement Learning
IEEE Robotics and Automation Letters (RA-L), Jul 2020
Links
Copyright, 2026